
Application engineering · Manufacturing review
Robot PCB Design & Assembly: Drives, Sensing and Control
Partition a robot controller into motor power, current sensing, logic and communications. Check shunt loss and amplifier headroom, then prepare the board and test information needed for an engineering review.
Preliminary files are welcome. Identify the board revision, quantity and the question you need to resolve.
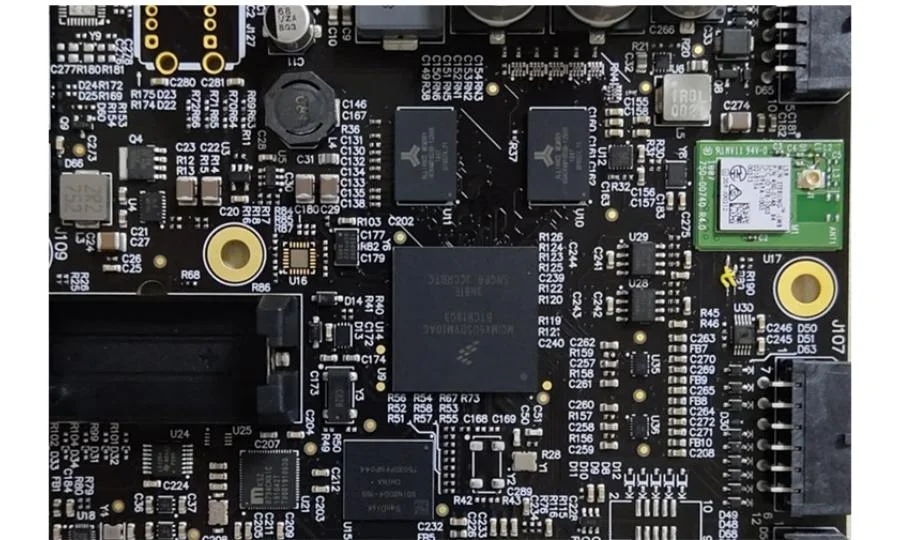
Robot PCB design spans power, sensing and computation
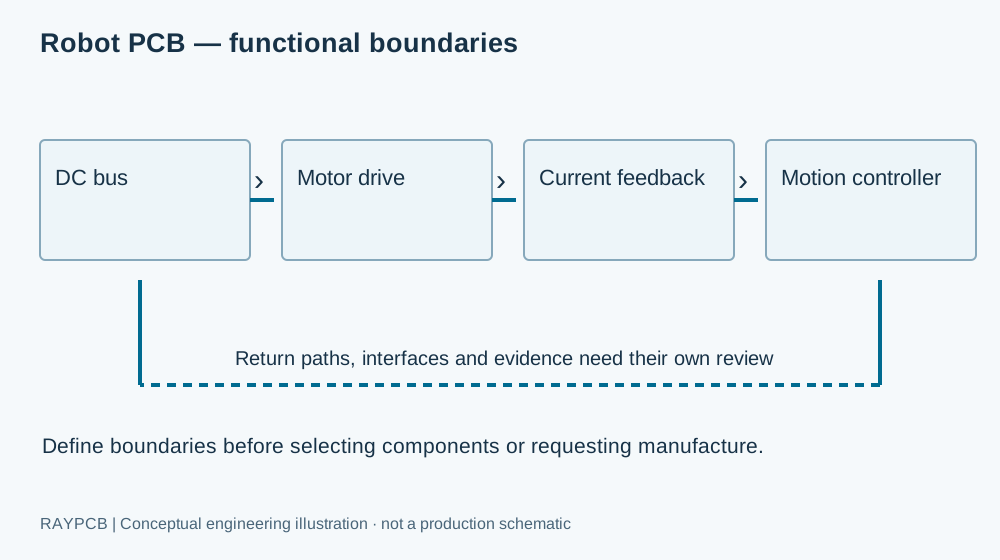
A robot PCB may be a motor-drive board, a motion controller, a sensor interface, a communications module or a combination of these functions. The architecture determines the manufacturing challenge. A compact compute board is dominated by routing, power integrity and package escape. A drive board adds high current, switching edges and heat. A sensor interface may be governed by noise and connector behavior. Define which role the board owns before comparing layer counts or assembly quotations.
The most useful starting document is a functional map showing the energy path, feedback path and external connections. Include what happens when a motor stalls, a sensor disconnects or a communication link stops. Those system decisions influence the circuit and its test points. This page focuses on general industrial and service-robot electronics, with practical current-sense planning and manufacturing preparation. It does not certify a safety function or supply a ready-to-run motion-control design.
| Decision | Why it matters | Bring to the review |
|---|---|---|
| Drive current | RMS heating and peak sensing are different checks | Waveform, shunt details and amplifier range |
| Feedback integrity | Power-trace resistance can contaminate sensing | Kelvin points, reference path and noise conditions |
| Bring-up access | Heatsinks and connectors can block a fixture | Programming points, test nodes and assembly sequence |
Partition the controller without breaking return paths
Place the switching stage around short, deliberate current loops. Keep low-level feedback away from rapidly changing switch nodes, while maintaining the reference structure required by the signal. A visual separation between power and logic is useful only when the actual currents and interfaces are understood. Cutting a ground plane can make a return path longer or force it through an unintended route. Review the complete loop rather than treating a split plane as a universal noise remedy.
Separate connector functions clearly: motor phases, DC input, encoder, communications and programming should be identifiable in the drawing and on the assembly. Consider cable strain, insertion access and maintenance errors. A keyed connector does not eliminate a labeling or harness-revision problem. If the board combines drive and control, identify the interface between those domains in the schematic and test plan. The industrial PCB guide expands the field-wiring and supply-interruption discussion.
Engineering workbench
Robot Current Sense Planner
Explore the worked example or enter your own assumptions. The result explains the calculation boundary and can be downloaded for an engineering enquiry. No project data is uploaded by this tool.
RAYPCB ENGINEERING
Industry EngineeringRobot Current Sense Planner
Loading Robot Current Sense Planner…
Current sensing: resistance is only the first decision
The current-sense planner calculates shunt voltage, DC or RMS loss and a simplified unipolar amplifier output. At 10 A through 2 mΩ, the shunt voltage is 20 mV and the dissipation is 0.2 W. With gain 20, the ideal signal contribution is 0.4 V. These numbers make the trade-off visible: a larger shunt produces more signal but also more voltage drop and heat. The result is not a shunt power-rating approval.
For pulsed current, use an appropriate RMS value for heating and separately examine peak voltage and transient behavior. A real amplifier adds offset, gain error, bandwidth limitations, common-mode constraints and output swing limits. The tool uses an entered output ceiling for a first headroom check; it does not select the ceiling from an ADC datasheet. Bipolar measurement and PWM-dependent sampling require a fuller model. Review the circuit at the worst relevant current and temperature, not only at nominal operation.
Kelvin routing and the measurement reference
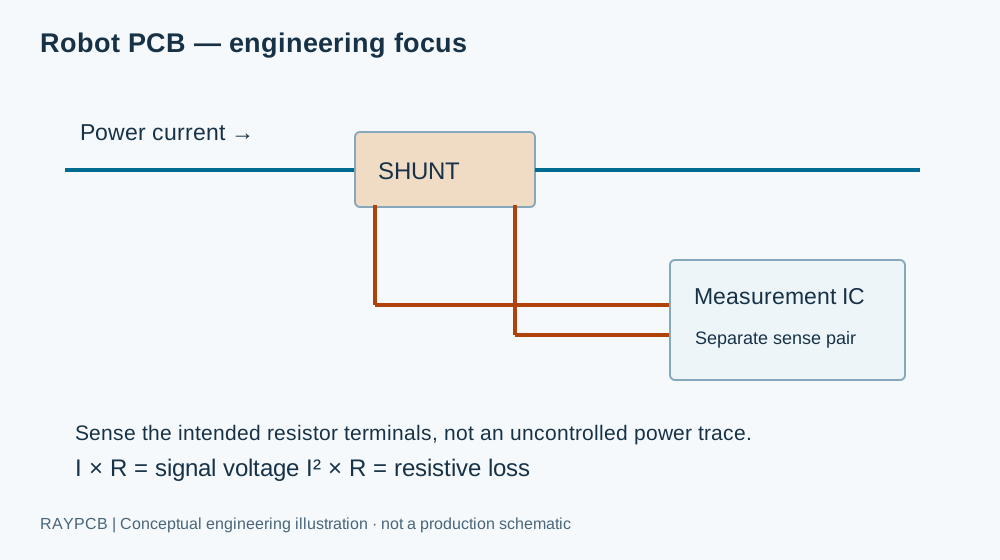
A shunt's power terminals and sense points should be treated as different routing tasks. Route the differential sense connections from the intended measurement points and avoid including an uncontrolled length of high-current copper in the measured resistance. Keep the pair's exposure to noisy fields similar and follow the amplifier's input-filter guidance. Component placement, copper geometry and the reference connection can matter as much as the nominal shunt tolerance.
The explanatory drawing shows the principle of a separate sense pair. It does not specify pad geometry or a complete differential filter. Use the selected resistor's terminal definition and the amplifier's recommended layout. Reserve measurement access for prototype investigation without making the sense path a long antenna. If a production fixture measures a related current or voltage, document how its connection differs from the control loop's own sensing path.
Choose drive ICs and reference schematics by operating conditions
The TI DRV8353 documentation provides an example of a three-phase gate-driver family and its evaluation resources. A gate driver controls external switching devices; it is not a complete motor power stage. Compare supply range, gate-drive capability, protection behavior, current-sense options, package and interface for the exact variant. Then review the external MOSFETs, gate resistors, bootstrap or supply components and layout together.
For the controller MCU or processor, record timing requirements, ADC trigger behavior, communication interfaces, memory and programming needs. The chip with the highest clock rate is not necessarily the best fit for a deterministic control task. Keep the software and hardware assumptions aligned, especially around fault flags and reset states. Manufacturer reference schematics are valuable starting evidence, but changes in motor, bus voltage, switching frequency and enclosure can change the design requirements substantially.
Stackup, copper and thermal design
Choose a stackup that gives critical signals suitable references and supports a practical power distribution network. Dense processors or fine-pitch drivers may justify additional layers, but more layers do not repair a poor switching-loop arrangement. The controlled impedance guide is relevant where communication or processor interfaces require defined transmission structures. Identify which nets actually need that control and include their requirements in the fabrication notes.
Motor-drive heat leaves through several paths: semiconductor package, copper, vias, interface material and mechanical structure. A heavy-copper board can reduce part of the resistance without solving a weak package-to-heatsink interface. Consider mounting pressure and electrically live thermal surfaces where applicable. Review trace loss and thermal assumptions with the power PCB guide. Keep simulations, calculations and measured temperatures distinguishable in the project records.
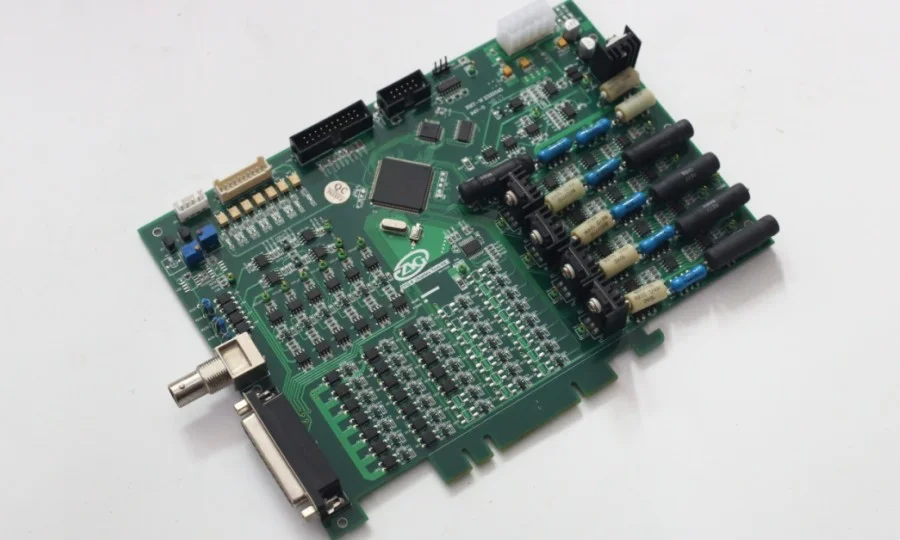
Bring-up access and a meaningful test strategy
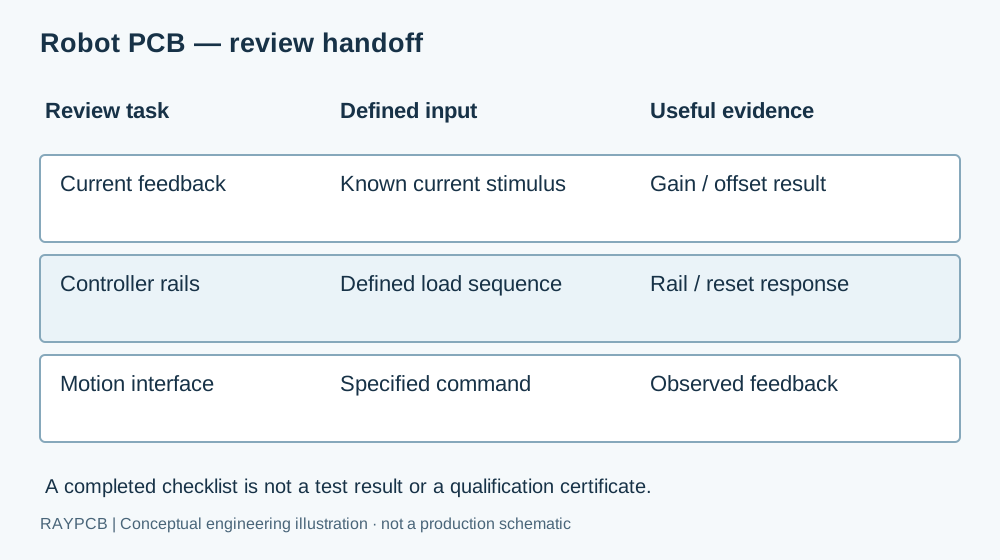
Reserve access to input rails, regulated supplies, programming signals and selected diagnostic nodes before the layout is frozen. An accessible reset or boot-mode point can save substantial first-build time. Check that test points remain reachable after tall connectors or heatsinks are fitted. Decide whether the board will be tested alone, with a load emulator or as part of a complete robot subsystem, because those arrangements provide different evidence.
A staged bring-up can begin with continuity and unpowered checks, then controlled rail verification, communication and sensing checks before a defined drive test. The actual procedure needs the design owner's limits and appropriate laboratory precautions. Production test should record the approved firmware and fixture revision along with measured results. AOI or X-ray may support assembly inspection but cannot demonstrate closed-loop stability or safe system response to a fault.
Assembly details that affect repeatability
Large connectors, thermal pads and power components can create an uneven soldering challenge. Discuss stencil design, thermal exposure and any selective soldering operation using the actual assembly. A connector that is easy to solder manually on a prototype may become a cost or consistency issue in repeat production. Support heavy parts mechanically where the design requires it, and specify the approved securing material and process rather than a vague instruction to add adhesive.
Component alternatives need technical approval. A pin-compatible driver or current amplifier may differ in timing, offset, fault behavior or software configuration. Preserve the exact approved BOM and document fitted options. Where calibration is required, define whether coefficients belong in firmware, nonvolatile memory or an external record. The assembly provider should not have to infer calibration ownership from an example prototype.
Prepare a quote around the robot subsystem
Send the board data, stackup, BOM, placement files and mechanical drawing, together with the board's role in the machine. Include bus voltage, current profile, cooling arrangement, connectors, test requirements and the expected quantity range. Identify whether motor testing, programming, coating or mechanical integration is part of the requested scope. Those activities can dominate the difference between two offers that appear to quote the same number of placements.
Use PCB Assembly for component sourcing and assembly discussion, and PCB Manufacturing for the bare-board requirement. The planner's downloadable brief can accompany your question about shunt sizing or measurement headroom. It carries the entered assumptions; it does not automatically populate the Contact form or approve the control circuit for manufacture.
For a civilian aerial platform, the drone PCB design guide focuses on controller rail allocation, sensor placement and peripheral startup. Keep that controller budget separate from propulsion drive sizing. The two boards may share a source while requiring different verification tasks.
Questions about robot control boards
Can one PCB contain motor power and sensitive sensors?
It can, but the feasibility depends on current loops, reference paths, thermal gradients, mechanical placement and the required signal quality. Partitioning and verification matter more than a rule that the functions must always be combined or separated. Review the proposed architecture before deciding. ### Does the shunt result define the maximum motor current? No. It estimates voltage and loss for the entered value. The motor, switching devices, connectors, protection, shunt pulse rating and thermal behavior all impose separate constraints. Use the result to identify questions for a complete power-stage review. ### What should a first prototype prove? Define its purpose explicitly: rail behavior, sensing accuracy, interface timing, mechanical fit or another measurable task. A prototype that moves a motor once has not established production repeatability or system safety. Record what was tested and what remains unresolved.
A focused next step
Bring the requirement. Identify the open question.
Send the available board files, quantity and revision with the operating conditions discussed above. State whether you need bare boards, assembly or a broader manufacturing scope.
Use the downloaded brief to explain your assumptions. The Contact form is independent; it does not automatically receive calculator entries. A project review determines the quotation and agreed build scope.
Technical references reviewed September 2026. Illustrations explain concepts. Product and equipment photographs do not establish project-specific qualification, test results or certification.