
RAYPCB · ENGINEERING GUIDE
PIR Motion Sensor Circuit: Optics, Filtering and Detection
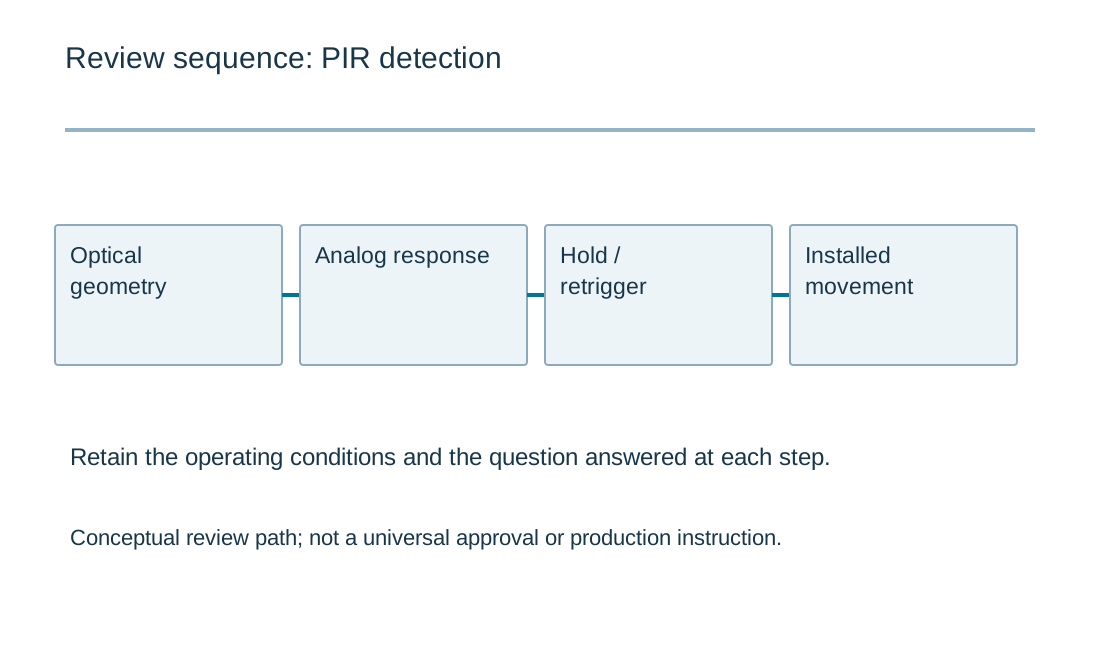
A PIR motion sensor circuit detects changes in infrared radiation at a pyroelectric sensing arrangement. The optics, sensing elements, analog filtering and decision logic work together to produce a motion indication. It does not directly identify a person or prove that a space is unoccupied when no event is detected.
This page explains the signal chain and the PCB questions behind it. The filter worksheet calculates two separate first-order RC corner frequencies. It is a way to inspect component assumptions, not a range predictor or a complete model of a commercial motion-detector module.
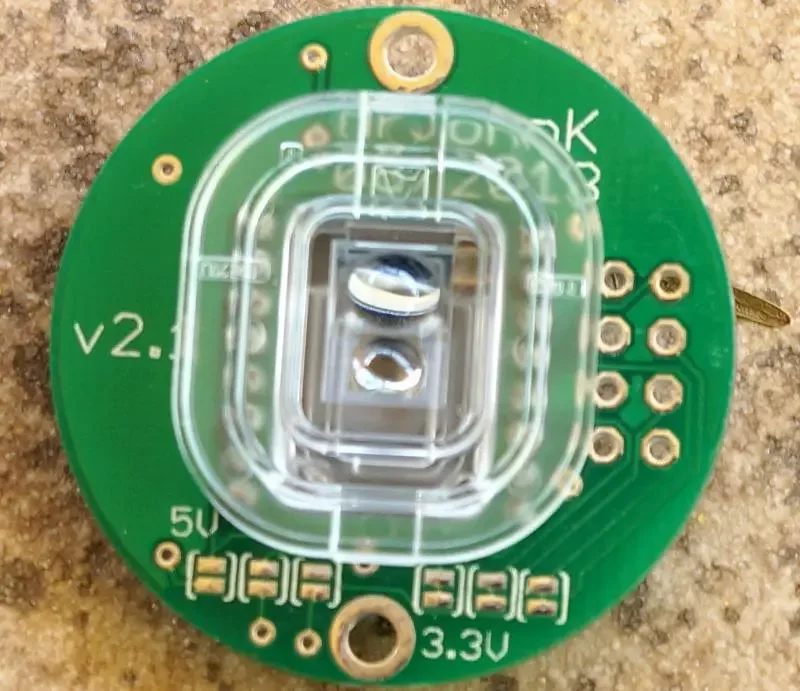
Begin with the optical field and intended movement
The lens or optical cover maps parts of the scene onto the sensing arrangement. Motion across the resulting zones can produce a changing signal, while movement along another path may produce a different response. Installation height, orientation and the thermal contrast of the scene therefore affect the observation.
Define the intended task: switching a light, detecting a movement event or another bounded function. Continuous presence detection is a different requirement from detection of changing radiation. A stationary person may not produce the same signal as a moving one. Do not turn a no-event output into a universal absence claim.
Use the exact sensor and lens documentation to establish geometry and assembly. A lens borrowed from another module may not match the element arrangement or focal relationship. The enclosure must allow the intended infrared path; a visually clear material is not automatically suitable at the sensor's wavelengths.
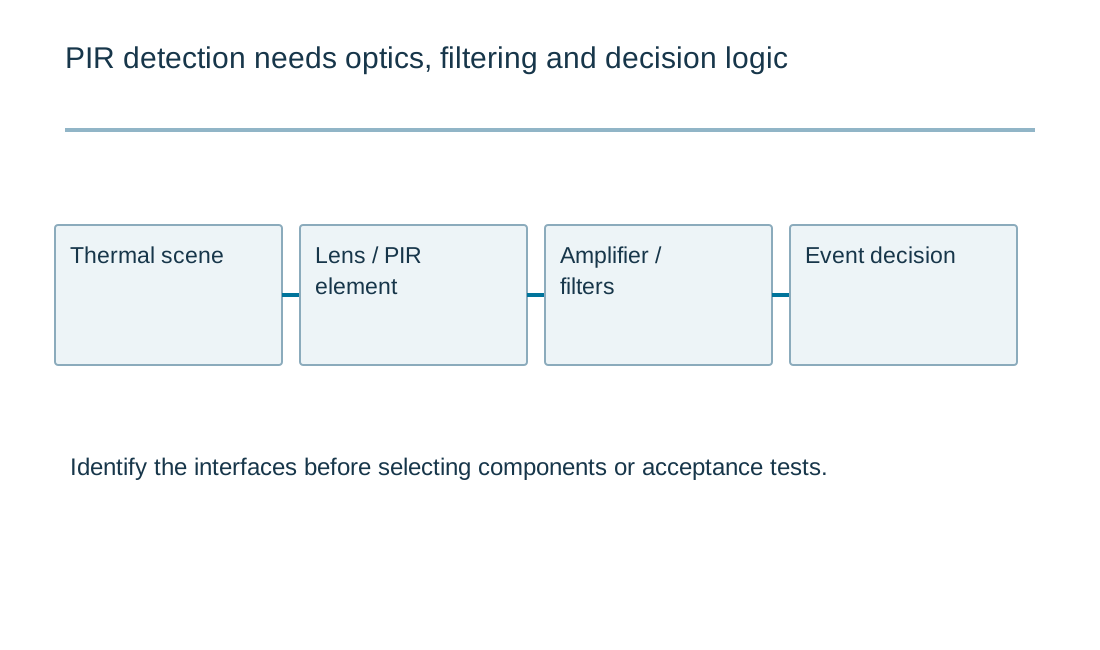
Follow the small signal through the front end
Identify the sensor's bias and output arrangement, then the amplifier, filter and decision stages. Some modules contain much of this circuitry internally; others expose a small analog signal. Do not apply an external front-end assumption to a module whose output is already a processed digital event.
TI's CIRCUIT060004 provides a documented example of PIR signal conditioning using amplification and filtering. It demonstrates the role of multiple stages but is not a universal prescription for every sensor and lens. A chosen circuit's gain, bandwidth and supply conditions must match the actual input and detection objective.
Keep amplifier input bias, offset, noise and output range in view. Excess gain can saturate a stage on a disturbance and delay recovery. A quiet-looking digital output can hide that analog condition. Provide observation points that allow the signal chain to be examined without adding excessive loading or interference.
| Review item | What to establish |
|---|---|
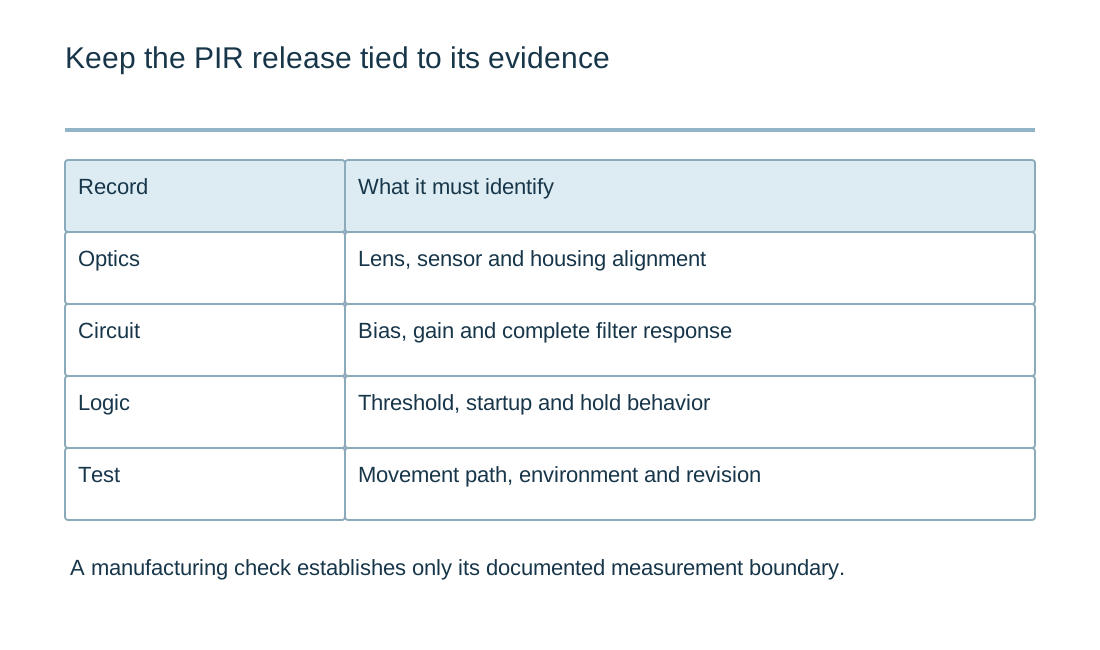
| Optics | Exact lens, element arrangement, mounting and intended movement. |
| Signal | Bias, gain, range and accessible observation points. |
| Filter | Individual RC corners versus complete loaded transfer response. |
| Logic | Thresholds, hold/retrigger, startup and recovery states. |
| Evidence | Defined movement test and electrical versus optical coverage. |
Interpret the RC worksheet correctly
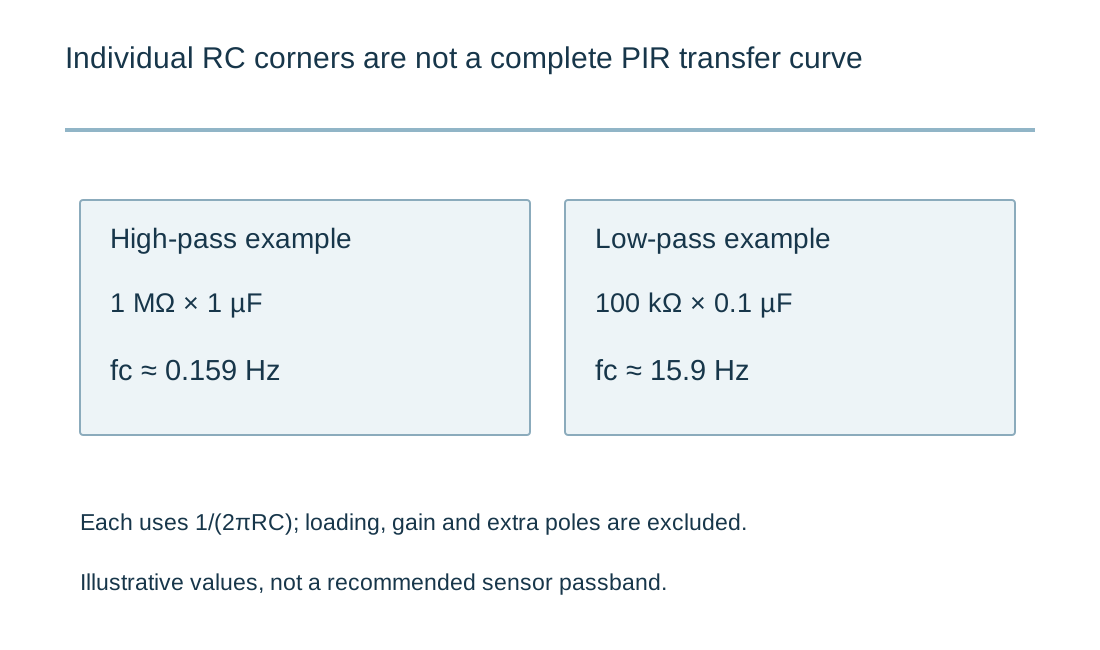
For a simple first-order stage, the corner frequency is 1/(2πRC). The worksheet calculates the entered high-pass and low-pass networks independently and compares their ordering. It does not combine amplifier gains, loading, additional poles or the sensor's response into a final transfer curve.
An illustrative 1 MΩ and 1 µF high-pass network gives about 0.159 Hz. A separate 100 kΩ and 0.1 µF low-pass network gives about 15.9 Hz. These example values are not recommended detection limits and are not the measured passband of the referenced TI design. A complete cascaded response needs the actual circuit and tolerances.
If the proposed high-pass corner exceeds the low-pass corner, the tool highlights the inconsistent intended ordering. Even a correctly ordered pair does not prove useful motion detection. The time signature depends on the optics, motion and thermal scene as well as electronics. Use calculation to frame a measurement, not to replace the installed test.
First-order PIR filter corner comparison
First-order PIR filter corner comparison
Use the current inputs and keep the assumptions
Load the example to inspect its units, then clear it before entering your own revision. Example values are deliberately labeled assumptions. Complete every field; an empty numeric input is not zero. Record the operating condition behind a value rather than copying the first number found on a component summary. For a comparison, keep the measurement boundary and units consistent.
Calculate after checking the inputs. Any edit invalidates the old result and disables its report download until you calculate again. An edited example remains identified as an example. Results and reports are generated locally without uploading a circuit or populating Contact. Attach the downloaded text manually if it helps explain the question. You can request a review directly without completing the tool.
| Input | What to establish before using it |
|---|---|
| Review reference | Nonconfidential revision label. |
| High-pass resistance · kΩ | Effective resistance in the actual first-order high-pass network. |
| High-pass capacitance · µF | Nominal capacitance. |
| Low-pass resistance · kΩ | Effective resistance in the separate low-pass stage. |
| Low-pass capacitance · µF | Nominal capacitance; gain and combined transfer curve excluded. |
Distinguish decision timing from analog bandwidth
Thresholds, pulse counting, hold time and retrigger behavior define how an analog event becomes an output. A long output hold can make a detector appear continuously active even though individual events are brief. A short hold may produce repeated switching that is unsuitable for the user task. Document the intended behavior rather than leaving module jumpers unexplained.
Startup settling and baseline recovery require explicit states. The system should know whether a module is ready to interpret events after power-up. A disturbance that saturates the analog path can also require recovery time. Test those transitions instead of considering only steady repeated motion in front of the device.
Noise and environmental changes may resemble useful signals. Evaluate likely disturbances from the installed supply, switching loads, airflow and changing thermal backgrounds. Do not claim immunity from a brief indoor demonstration. The test plan should name the relevant conditions and separate missed intended events from false outputs.
Lay out the PCB with the installed product in mind
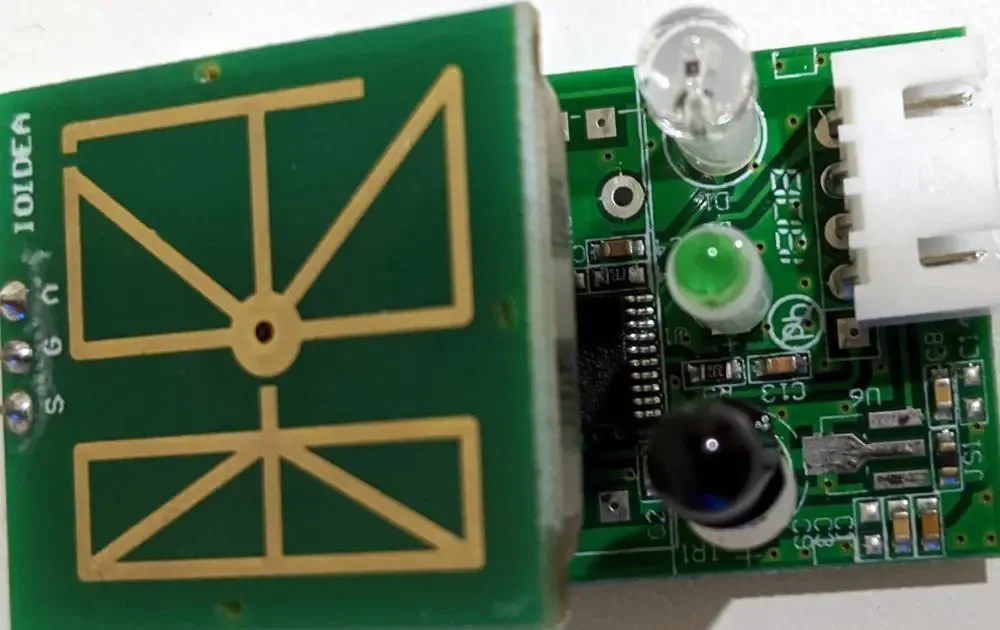
Keep sensitive input paths short and appropriately referenced, with local decoupling and separation from switching-current routes. A relay, radio or LED driver on the same board can create electrical or thermal disturbances. Observe the detector while those functions operate, not only while they are disabled for a clean laboratory trace.
High-value resistors and low-frequency coupling networks can be sensitive to leakage and contamination. Select components and assembly processes for the actual environment and input requirements. Additional coating may affect the optical or mechanical interface, so exclusions and material compatibility should be controlled.
The electret microphone guide shares some low-level signal-conditioning concerns, but audio bandwidth and acoustic coupling differ from PIR sensing. A capacitive touch input observes another physical interaction. Sharing an enclosure does not make their thresholds or filtering interchangeable.
Verify detection and release the assembly boundary
Create a repeatable movement or stimulus method with stated path, distance, orientation and environmental conditions. Retain lens, sensor, enclosure and firmware revisions. Electrical signal injection can verify downstream processing while bypassing optics and the sensing element; label that test accordingly.
For production, decide whether acceptance checks only the board's electrical response or the complete module with optics. Define fixture alignment and the required event behavior. A powered indicator LED is not enough to establish the intended detection coverage. Conversely, a full application validation need not be described as an inspection performed on every board unless it actually is.
Provide RAYPCB the schematic, board files, BOM, lens/mounting drawing, quantity and requested test evidence. Identify the open analog, optical or assembly question. The worksheet report can show the nominal filter assumptions, while actual detection suitability depends on the complete installed system and its verified operating conditions.
Validate the installed measurement chain
The sensor measures a local physical condition through a particular mounting and signal path. Its nominal resolution is not the accuracy of the installed system. Define the quantity, reference, useful response time and environment before deciding that a high-rate output or a long decimal value is meaningful.
Preserve raw observations, calibration coefficients and the conditions under which they were obtained. Check intermediate points and relevant environmental changes rather than only fitting endpoints. Separate invalid, stale and out-of-range data from valid low readings. Manufacturing tests should verify the electrical and assembly tasks actually agreed; field calibration and application validation need their own methods. Keep personal or confidential project details out of public worksheet labels and attach controlled records through the normal inquiry process.
Standards, source context and limits
Use the exact device revision and application conditions when applying manufacturer guidance. Reference designs are evidence about a specified implementation, not automatic validation of a modified board. Workmanship inspection, functional verification, product safety and application performance are different acceptance tasks. Public summaries do not replace the applicable licensed standards or a project-specific acceptance specification.
For fabrication scope and the agreed construction requirements, see PCB manufacturing.

