
RAYPCB · ENGINEERING GUIDE
MEMS Motion Sensor PCB: Mounting, Axes and Sampling
A MEMS motion sensor PCB connects sensitive mechanical structures to electrical sampling and software interpretation. Accelerometers and gyroscopes can share a small package, but board stress, mounting, axis definitions and data timing still affect the result. A successful register read proves communication, not accurate motion measurement in the finished product.
This page focuses on PCB integration and a repeatable hardware handoff. The payload worksheet estimates raw sample traffic and FIFO coverage for an explicitly defined frame. It does not calculate position accuracy, validate sensor fusion or replace the selected device's timing and assembly guidance.
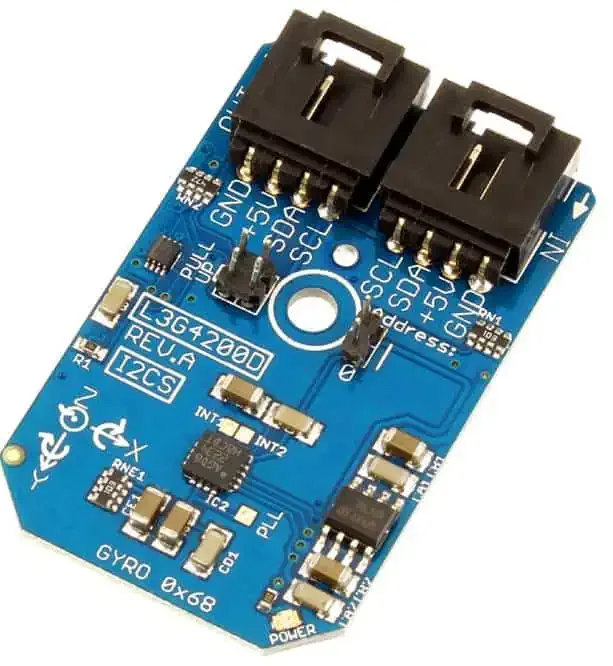
Define the measured motion and coordinate frame
An accelerometer and a gyroscope measure different quantities. Their raw outputs need scale, sign and reference definitions before an application can combine them. A stationary accelerometer can observe gravity according to orientation; that does not make its output a direct position measurement. Integrating imperfect data can accumulate error that a simple board specification does not resolve.
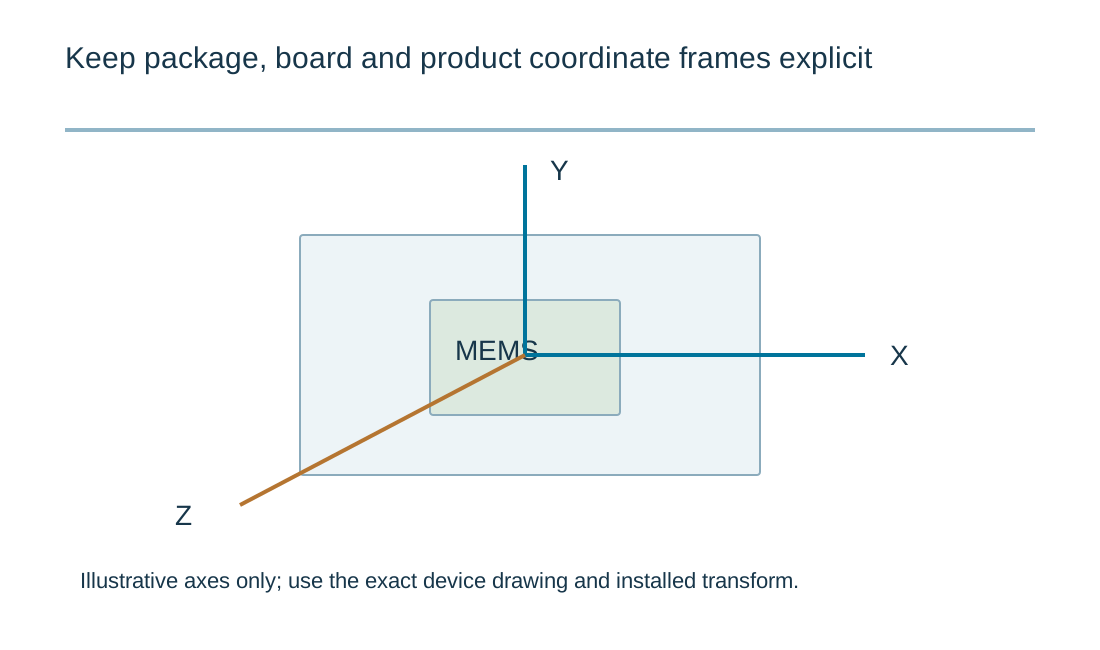
Draw sensor-package axes, PCB axes and installed product axes in the same release. Include orientation and any required transformation in firmware documentation. A sensor rotated on the board may communicate normally while producing an incorrect system interpretation. Physical silkscreen and a controlled assembly drawing can help prevent that error.
Choose range, output rate and bandwidth from the intended motion and environment. A larger range may change resolution or noise behavior, and a higher output rate does not guarantee a wider valid measurement bandwidth. Use the exact device mode and filter configuration. Preserve those settings beside the data used for evaluation.
Treat board mechanics as part of the sensor path
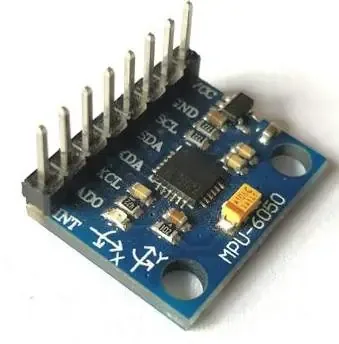
The sensor follows the motion of its local mounting region, which may differ from the object the user wants to measure. Board flex, housing resonance, cable forces and loose mounting can contribute. A long flexible PCB tongue may be an unintended mechanical filter or resonator rather than a neutral carrier.
Assembly and mounting stress can shift sensor behavior. ST's TN0018 provides primary guidance for handling, soldering and mounting its MEMS devices, including the need to consider mechanical effects. Apply the selected component's current requirements; do not turn one manufacturer's example footprint into a universal rule for all inertial sensors.
Review the sensor's relationship to screws, board edges, heat sources and mechanically loaded parts. The final housing matters as well as the bare PCB. If calibration is performed before mounting, establish whether subsequent assembly changes the relevant offset or alignment. Keep the evaluated mounting condition reproducible.
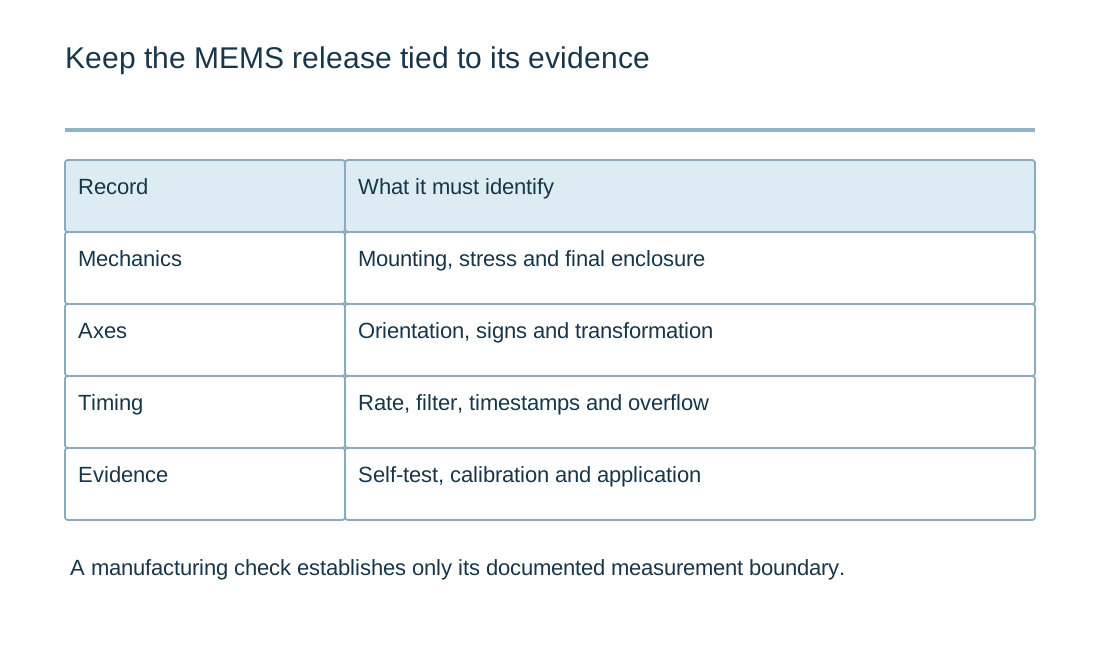
| Review item | What to establish |
|---|---|
| Axes | Package, PCB and installed coordinate frames with signs. |
| Mechanics | Mounting, board stress, resonance and final enclosure. |
| Timing | Device mode, rate, filtering, timestamps and overflow handling. |
| Payload | Stored frame width, usable FIFO and actual transport overhead. |
| Evidence | Self-test, calibration and application validation kept separate. |
Implement power, interface and sample timing
Follow supply decoupling and interface requirements for the exact device. Identify which signals indicate data ready, FIFO state and errors. A host that polls quickly can still read old samples or inconsistent multi-byte data if it ignores the documented acquisition method. Preserve frame identity and timing rather than assuming every bus transaction is a new observation.
If acceleration and rotation run at different rates, define how their records are associated. Equal array positions do not establish simultaneous sampling. Timestamp source, clock drift and host latency may matter for the application. The simplified payload tool assumes complete equal-rate frames and explicitly excludes those synchronization questions.
Interrupt handling and FIFO draining should tolerate expected host delays. Define overflow behavior and how the application identifies missing samples. Silently joining data across an overflow can corrupt later analysis. A reliable communication link should carry validity information as well as the numerical axes.
Calculate payload before choosing a service interval
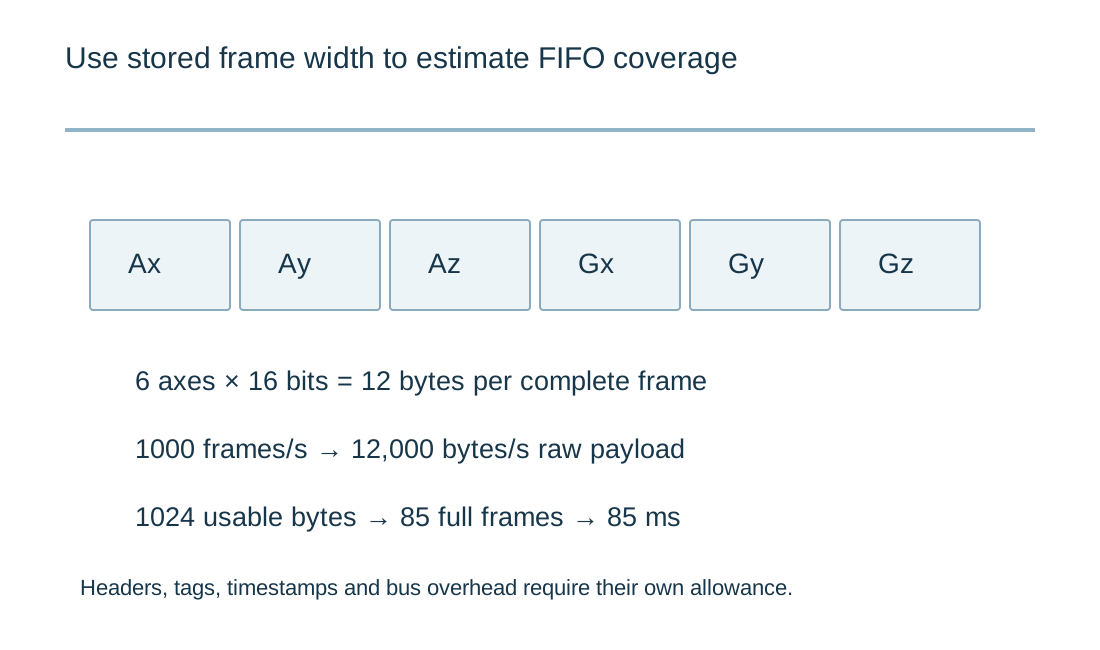
The worksheet multiplies stored axes by stored bits per axis and complete frames per second. Storage width is the number of bits actually retained in each frame, not necessarily the sensor's nominal resolution. Headers, timestamps, tags and transport overhead must be included separately unless already represented in the entered frame.
For six axes stored at 16 bits each and 1000 complete frames per second, the raw payload is 12,000 bytes per second. A 1024-byte usable FIFO holds 85 complete 12-byte frames, representing 85 ms in this model. The remaining four bytes do not hold another complete frame. This is an arithmetic example, not the FIFO format of every six-axis device.
Bus capacity must cover more than the raw payload. Addressing, commands, gaps, competing devices and host scheduling reduce available service time. The FIFO duration is not a recommended maximum interrupt latency without margin. Review the real protocol and worst expected delays, then verify that samples remain complete and ordered.
MEMS sample payload and FIFO coverage
MEMS sample payload and FIFO coverage
Use the current inputs and keep the assumptions
Load the example to inspect its units, then clear it before entering your own revision. Example values are deliberately labeled assumptions. Complete every field; an empty numeric input is not zero. Record the operating condition behind a value rather than copying the first number found on a component summary. For a comparison, keep the measurement boundary and units consistent.
Calculate after checking the inputs. Any edit invalidates the old result and disables its report download until you calculate again. An edited example remains identified as an example. Results and reports are generated locally without uploading a circuit or populating Contact. Attach the downloaded text manually if it helps explain the question. You can request a review directly without completing the tool.
| Input | What to establish before using it |
|---|---|
| Review reference | Nonconfidential revision label. |
| Stored axes | Integer; acceleration and rotation may use different sample rates. |
| Stored bits per axis | Actual storage width, not nominal ADC resolution. |
| Complete frames per second | Synchronous equal-rate model. |
| Usable FIFO bytes | Exclude headers, timestamps and reserved capacity if not included in the frame. |
Distinguish self-test, calibration and application evidence
A device self-test exercises a defined internal behavior. It can be useful for diagnostics but does not automatically establish full scale accuracy, alignment or mechanical installation quality. Read what the selected device's self-test actually verifies and how its limits apply to the configured mode.
Calibration may address offset, scale or cross-axis effects under a defined procedure. Keep coefficients with the sensor identity, temperature conditions and firmware version. Verify at independent orientations or stimuli appropriate to the measurement. A stationary zero-rate observation alone cannot establish behavior over the complete motion range.
For vibration work, preserve mounting, excitation, bandwidth and sample timing. For a motion controller, distinguish the sensor observation from the stepper command rate. A PIR detector provides yet another kind of movement indication; it cannot substitute for inertial data merely because both pages use the word motion.
Release assembly and test requirements together
Provide exact sensor part, package orientation, footprint, keepouts and applicable handling instructions. Include the mechanical mount and any restrictions on cleaning or processing established for that component. Identify whether final calibration takes place before or after enclosure assembly and who owns the procedure.
The manufacturing test should define communication, configuration verification and any required physical stimulus. A readout within a plausible range is a useful gross check but not complete motion calibration. Record hardware and test-program revisions and retain the settings needed to reproduce the observation.
For a RAYPCB inquiry, send the controlled board files, BOM, quantity, mounting drawing and acceptance scope. Identify unresolved questions about stress, axis alignment, acquisition or fixture access. The payload report can clarify a data-handling assumption, while actual hardware and measured evidence determine the motion performance of the finished product.
Validate the installed measurement chain
The sensor measures a local physical condition through a particular mounting and signal path. Its nominal resolution is not the accuracy of the installed system. Define the quantity, reference, useful response time and environment before deciding that a high-rate output or a long decimal value is meaningful.
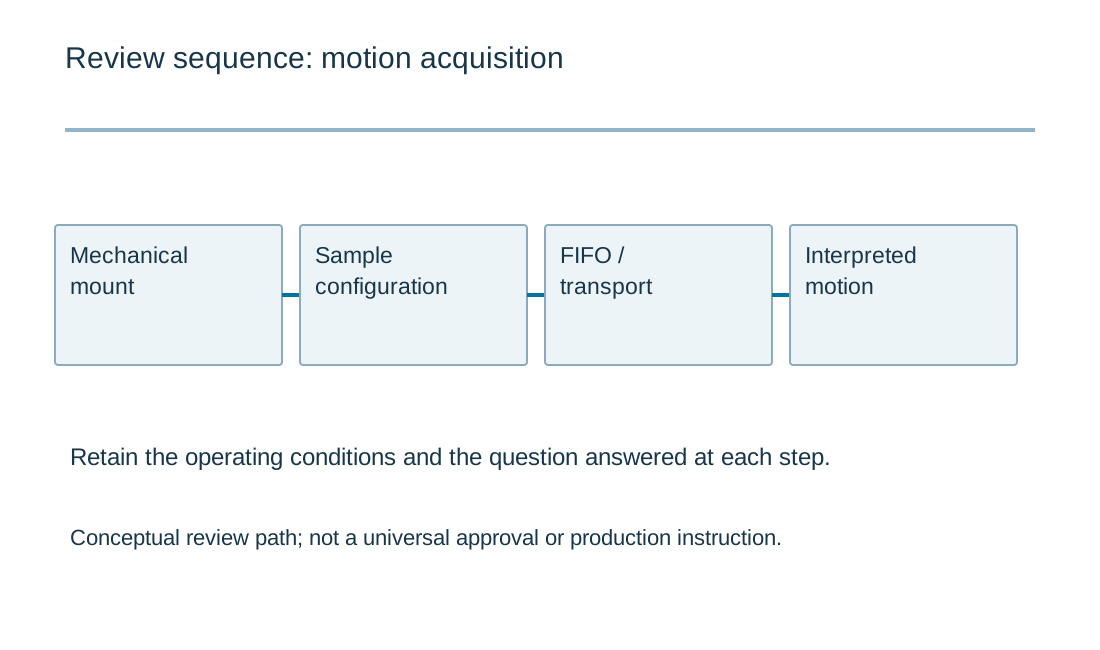
Preserve raw observations, calibration coefficients and the conditions under which they were obtained. Check intermediate points and relevant environmental changes rather than only fitting endpoints. Separate invalid, stale and out-of-range data from valid low readings. Manufacturing tests should verify the electrical and assembly tasks actually agreed; field calibration and application validation need their own methods. Keep personal or confidential project details out of public worksheet labels and attach controlled records through the normal inquiry process.
Standards, source context and limits
Use the exact device revision and application conditions when applying manufacturer guidance. Reference designs are evidence about a specified implementation, not automatic validation of a modified board. Workmanship inspection, functional verification, product safety and application performance are different acceptance tasks. Public summaries do not replace the applicable licensed standards or a project-specific acceptance specification.
For fabrication scope and the agreed construction requirements, see PCB manufacturing.